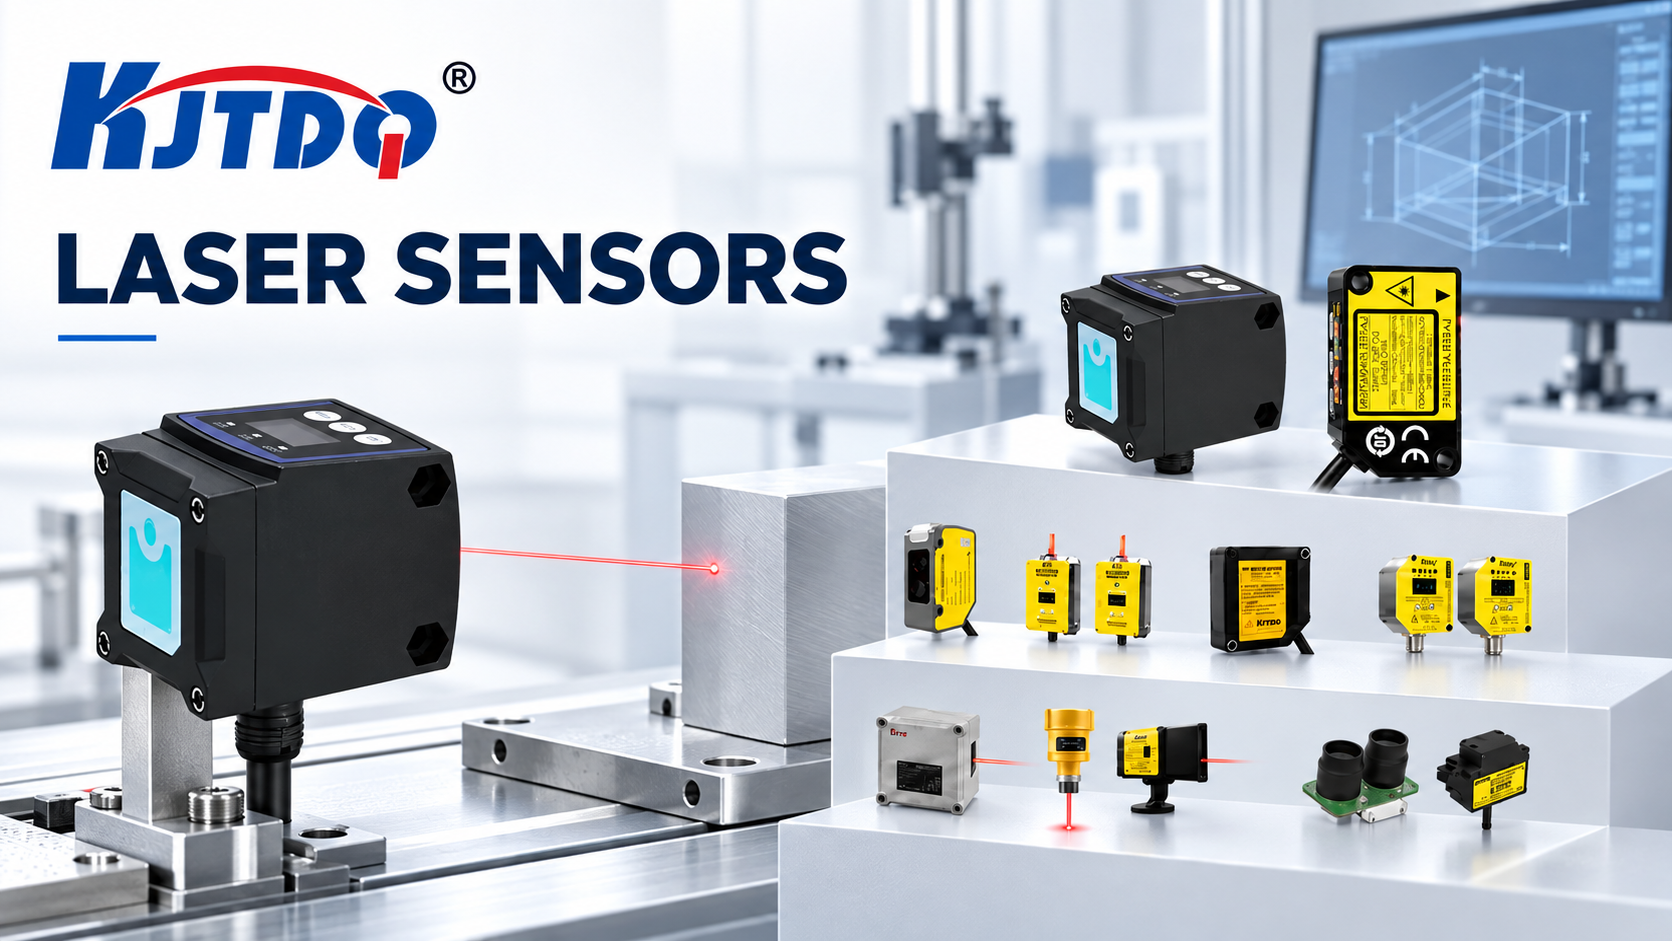
A laser distance sensor turns unstable on dark or glossy targets because the returned light is too weak (dark surfaces absorb), misdirected (glossy surfaces reflect specularly, away from the receiver), or both — and target angle, spot position, ambient light, vibration and configuration margins then decide whether the sensor can still evaluate the signal. The first safe check is geometric: confirm the target angle and spot position against the setup at commissioning. Never look into the beam or place reflective tools in the beam path; configuration changes belong to the exact model manual.
Key Takeaways
- Dark and glossy fail for opposite reasons. Dark surfaces return little light (signal-starved measurement); glossy surfaces return plenty of light but at the wrong angle (specular reflection misses the receiver). Both show up as dropouts, spikes or noise.
- Target angle is often the real variable. A glossy target that reads well at near-perpendicular incidence can fail at a few degrees of tilt because the reflected cone leaves the receiver aperture.
- Separate optical causes from mechanical and electrical ones. Vibration, marginal measuring range, slow response settings and electrical noise produce similar-looking instability — the diagnostic sequence below separates them.
- Model-specific settings are manual territory. Averaging, measurement rate and exposure-related parameters differ by model; this guide tells you which knob categories exist, not what value to enter.
- Some surfaces are simply hard targets. If geometry and configuration cannot recover the margin, a different measuring principle (eddy current for conductive targets, radar for long range) may fit better — see the comparison guides (distance-technology comparison, eddy-current vs laser displacement comparison).
Symptom Definition
This article covers instability of the measured distance value on a stationary or moving target:
- Dropouts — the output periodically reports no valid measurement;
- Spikes — single readings jump far beyond physical plausibility;
- Elevated noise — the reading wanders beyond the repeatability observed at commissioning;
- Range-dependent failure — stable near, unstable far (or the reverse).
Fluctuation that appears only while the machine moves (stable when stopped) is treated here as a vibration/motion contributor and is covered in the diagnostic sequence; the dedicated moving-target selection questions are covered in the moving-target distance guide (moving-target distance guide).
Cause Table
| Cause category | Why it creates the symptom | Safe check | Corrective direction | Technician required? |
|---|---|---|---|---|
| Low reflectivity (dark target) | Weak return reduces signal-to-noise; the sensor discards readings (dropouts) or accepts noise (spikes), worst at long range | Compare readings on the dark target vs. a light matte target at the same distance | Shorten the measuring distance; increase averaging per manual; reselect a model/range with margin for dark targets | No for comparison test; Yes for configuration on unfamiliar models |
| Specular reflection (glossy target) | A mirror-like surface sends the beam away from the receiver except near perpendicular incidence; small tilts cause dropouts | Slowly vary the sensor-to-target angle (sensor at rest, machine stopped) and watch stability | Re-mount at near-perpendicular incidence; use a slight deliberate tilt only if the manual recommends it; matte the surface where process allows | Yes for re-mounting near moving parts |
| Target angle / curved surface | Angled or curved targets steer the return cone; cylindrical parts are effectively glossy in one axis | Check whether instability correlates with target orientation or position across the spot | Reposition so the spot lands on a flat, perpendicular region; reduce spot-to-edge effects | No for observation; Yes for repositioning hardware |
| Spot position / target edges | The spot straddles an edge, hole or step; the return mixes two distances | Watch the reading as the target traverses; note instability at specific target positions | Move the measurement point away from edges; consider a smaller-spot model | No |
| Ambient light | Strong light adds background noise to an already weak return — dark target + sunlight is the worst combination | Shade the measurement point temporarily; compare day/night behavior | Shield the point; re-aim; verify the model's ambient-light rating in its data sheet | No for shading test |
| Vibration / target motion | Relative motion moves the spot across surface texture; each sample "sees" a different micro-geometry — stable when stopped, noisy when running | Compare readings machine-stopped vs. machine-running at the same nominal distance | Stiffen mounting; increase averaging per manual; verify the measurement rate against target speed | Yes if machine must run during verification |
| Measuring-range margin | Operating near the model's range limit on a dark target leaves no signal reserve | Compute the actual distance against the model's stated range for the target type (data sheet) | Move closer, or reselect a model whose range covers dark targets at the required distance | Yes for reselection validation |
| Response / output configuration | Measurement rate, averaging or filter settings mismatched to target speed make real surface variation look like instability | Review current settings against the manual's guidance for the target speed | Adjust per the exact model manual; do not copy settings from another model | Yes — configuration changes |
| Cable noise / supply | Electrical noise or low supply corrupts the analog/serial output — instability persists even on a good target | Check whether instability persists on a white matte target at short range; inspect cable routing near drives | Separate signal from power cables; verify supply; grounding per manual | Yes — electrical checks |
Diagnostic Sequence (Least Invasive First)
- Baseline on a known-good target. Point the sensor at a light, matte, flat target at the same distance. If instability remains, the problem is electrical/configuration, not the target — skip to steps 7–8.
- Characterize the target. Note color, gloss, curvature, angle and surface texture where the spot lands. Photograph the spot position.
- Check the spot position. Confirm the spot does not straddle edges, holes or steps at any point in the target's travel.
- Run the shading test. Shield the measurement point from ambient light during a fault window; if stability improves, ambient light is a contributor.
- Check the angle. With the machine stopped, confirm the sensor face is near-perpendicular to a glossy target; note any tilt introduced since commissioning.
- Compare stopped vs. running. If readings are stable when stopped and noisy when running, treat vibration/motion as primary: inspect mounting stiffness and review averaging/rate settings per the manual.
- Review configuration against the manual. Measurement rate, averaging and output filter — confirm they match the target speed and the model's documented options. This step requires the exact model manual.
- Verify range margin and electrics (qualified technician). Confirm the operating distance suits the model's range on the actual target reflectivity; then supply, cable routing and grounding checks on de-energized circuits where possible.
Conditional Corrective Actions
- If dropouts occur only on the dark target at distance → shorten the distance or reselect a model with range margin for low-reflectivity targets; increasing averaging helps stability but slows response — check the speed trade-off per manual.
- If a glossy target reads only near perpendicular → re-mount for near-perpendicular incidence; if the process prevents it, discuss alternative geometries with support before modifying brackets.
- If instability tracks target edges → relocate the measurement point or choose a smaller-spot model.
- If stopped-vs-running comparison indicts vibration → stiffen the mount first; use averaging as the second lever, not the first.
- If the application fundamentally defeats the laser (black rubber at long range, mirror at forced angle) → evaluate eddy-current displacement for conductive targets (eddy-current vs laser displacement comparison) or radar for longer ranges and dusty environments (distance-technology comparison); the laser family comparison (laser taxonomy comparison) explains where each laser technology fits.
Replacement and Reselection Criteria
Reselect rather than reconfigure when:
- the required distance on the actual target reflectivity exceeds the model's documented range;
- the target speed requires a measurement rate the model cannot sustain with the averaging needed for stability;
- mounting geometry cannot achieve a workable incidence angle;
- the target surface (conductive) and required precision favor eddy-current measurement, or the environment (dust, long range) favors radar.
For any reselection, send the target photos and geometry listed below — dark/glossy behavior cannot be confirmed from datasheets alone; a sample test is the deciding step.
Information to Send KJT Sensors Support
- Exact model number and current configuration (photo of settings/display where applicable);
- Target photos showing color, gloss, curvature and the laser spot position;
- Sensor-to-target distance, incidence angle and mounting geometry (sketch or photo);
- Reading behavior: dropouts/spikes/noise, stopped vs. running, near vs. far;
- Ambient-light conditions at the measurement point;
- Required measurement rate and the target's motion profile.
Frequently Asked Questions
Why do dark targets weaken a laser return?
Dark surfaces absorb a large share of the incident light instead of scattering it back, so the receiver works with a weak signal. At short range the margin may still be adequate; at longer distances the return falls below the level the sensor can evaluate reliably, producing dropouts or noise. The fix is geometric (shorter distance, better angle), configurational (averaging per the manual) or selectional (a model with range margin for low-reflectivity targets) — in that order.
Why can glossy targets redirect the beam?
A glossy surface behaves partly like a mirror: it reflects the beam in one preferred direction rather than scattering it. If that direction is away from the receiver — which happens as soon as the surface tilts — the sensor sees no return even though plenty of light came back. Near-perpendicular mounting restores the geometry; deliberate small tilts should only be used if the exact model manual recommends them.
Which checks require the exact model manual?
All configuration changes: measurement rate, averaging/filter settings, output scaling and any teach or calibration procedure — the available settings and their ranges differ by model, and values copied from another model can make stability worse. Any procedure involving beam access or opening the device also requires the manual and compliance with its laser-safety instructions.
Is a laser distance sensor the wrong choice for black rubber or mirror surfaces?
Sometimes. Black rubber at long range and mirror-finish targets at uncontrolled angles are hard cases for optical triangulation/ranging. Conductive targets may suit eddy-current displacement sensors; long ranges and dusty environments may suit radar. Send target photos and geometry to support — the decision depends on distance, precision and speed, and a sample test settles it.
Conclusion
Dark targets starve the return; glossy targets misdirect it. Verify on a known-good target first, then work through spot position, shading, angle and the stopped-vs-running comparison before touching configuration — and treat all configuration changes as manual-plus-model work. If geometry and settings cannot recover the margin, reselect with a sample test rather than living with dropouts. Never look into the beam, and never defeat the product's safety features during any check.
Sources
- KJT Sensors, Service & Support — https://www.kjt-sensors.com/list-services.html (verified 2026-10-10)
- KJT Sensors internal category knowledge base: laser sensors (measuring range up to 30 m, IP67 on selected models) — version current at drafting
- General laser triangulation/time-of-flight engineering practice (reflectivity, specular reflection, spot geometry; no third-party claims)
URL NOT REVERIFIED: the KJT Sensors laser category page (list-jgcjcgq) returned no retrievable content at run time (2026-10-10, third occurrence across sessions); it is therefore not linked in this public draft. Restore the link after a successful manual recheck.
Contact Technical Support
Send target photos, the measuring distance and your mounting geometry via the KJT Sensors service page — include whether readings are stable when the machine is stopped, and a measurement engineer will help isolate the cause or arrange a sample evaluation.
https://www.kjt-sensors.com/
KJT Sensors